Embodied at Sea

Imitation Learning for Multi-Task Underwater Manipulation

[In Submission]

Greta Perez-Haiek*¹, Luca Macesanu*¹, Kevin Angers¹, Mohammed Imam¹, Dr. Timothy Gambin†², Dr. Christopher Clark†¹

* Equal contribution ¹ New York University ² University of Malta † Advising role

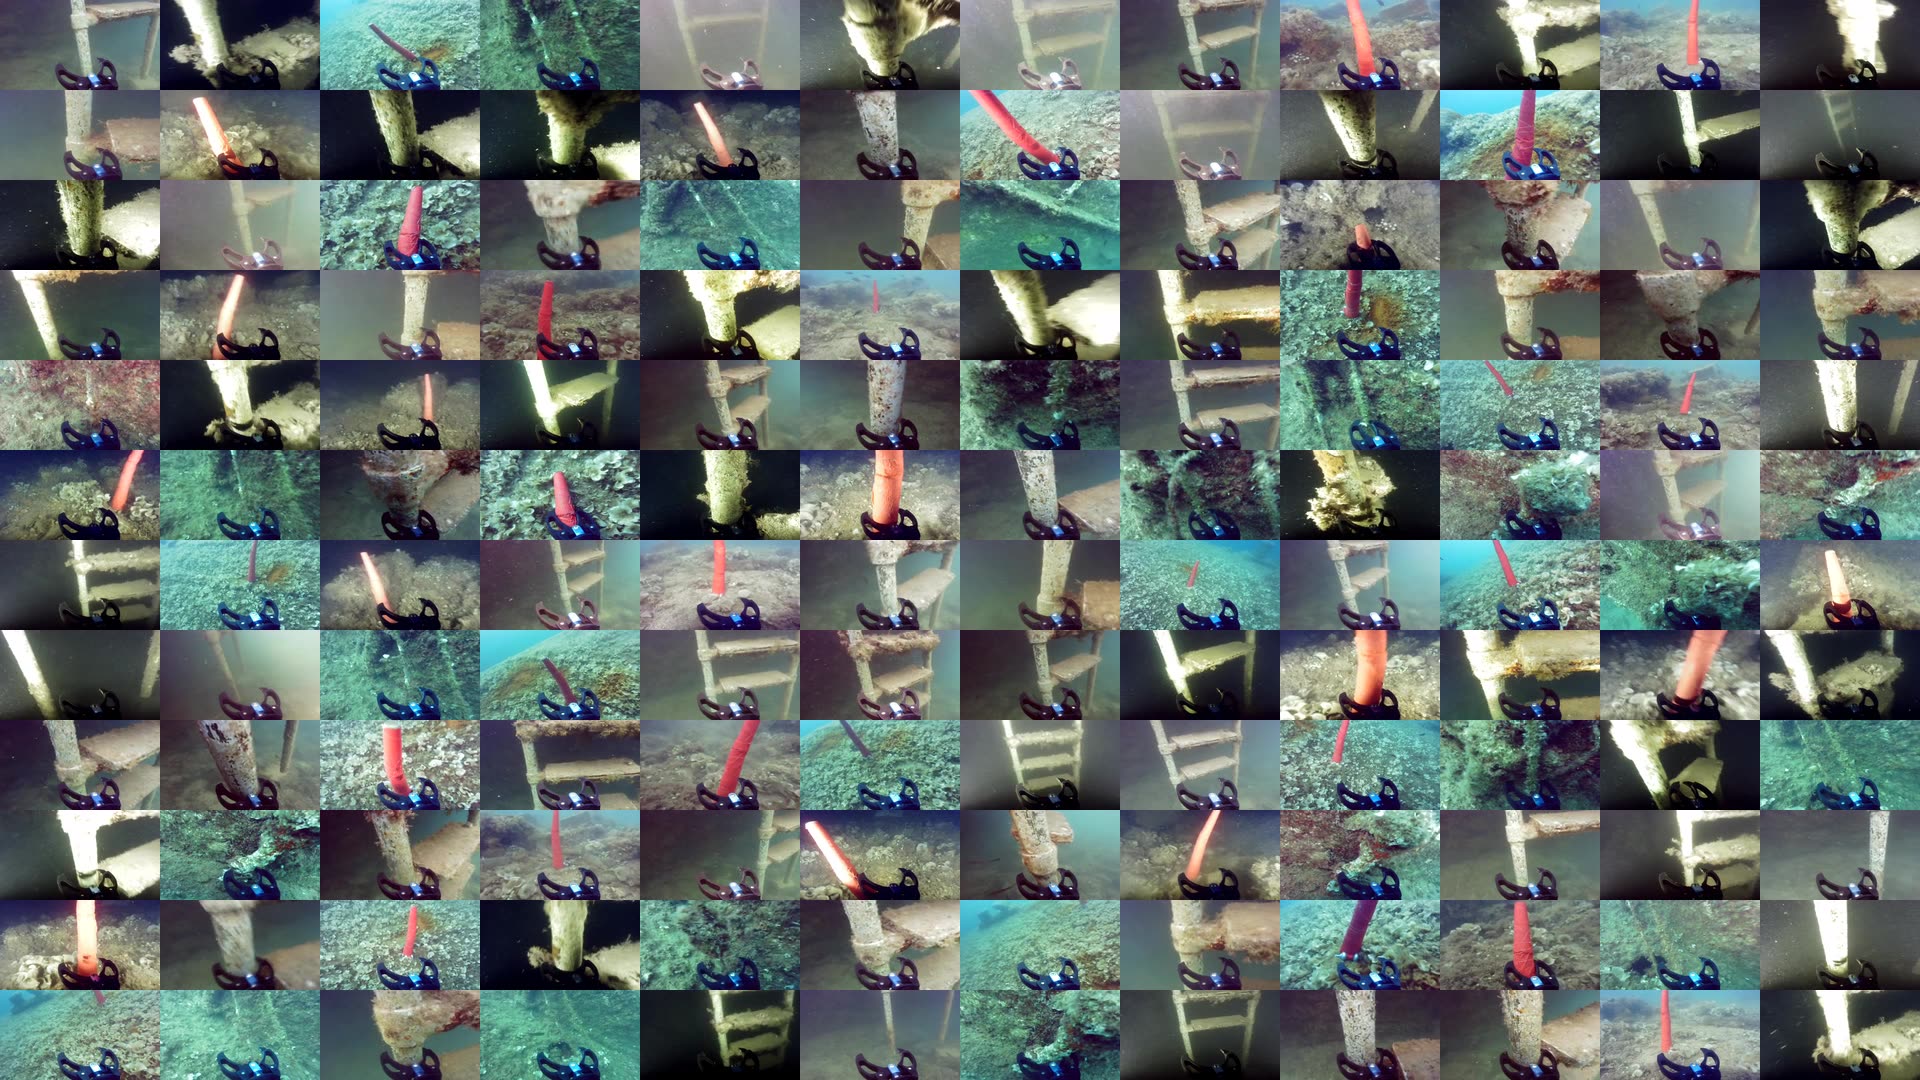
Above: 144 Unique, Successful ACT and SmolVLA rollouts in the wild

IROS 2026 ROSE Workshop contributor · See our presentation

Team & Contact

New York UniversityCenter for Robotics & Embodied Intelligence (CREO)  ·  Lab for Autonomous & Intelligent Robotics (LAIR)
University of MaltaDepartment of Classics & Archaeology
New York UniversityCREO / LAIR
Greta Perez-Haiek

Greta Perez-Haiek*

gp2583@nyu.edu
Luca Macesanu

Luca Macesanu*

lim2045@nyu.edu
Kevin Angers

Kevin Angers

kevin.angers@nyu.edu
Mohammed Imam

Mohammed Imam

mki4908@nyu.edu
Timothy Gambin

Dr. Timothy Gambin†

timmy.gambin@um.edu.mt
Christopher Clark

Dr. Christopher Clark†

c.clark@nyu.edu

* Equal contribution     † Advising role
NYU Center for Robotics and Embodied Intelligence LAIR — Lab for Autonomous and Intelligent Robotics University of Malta

Thank you to Heritage Malta for assisting in real-world underwater deployments!